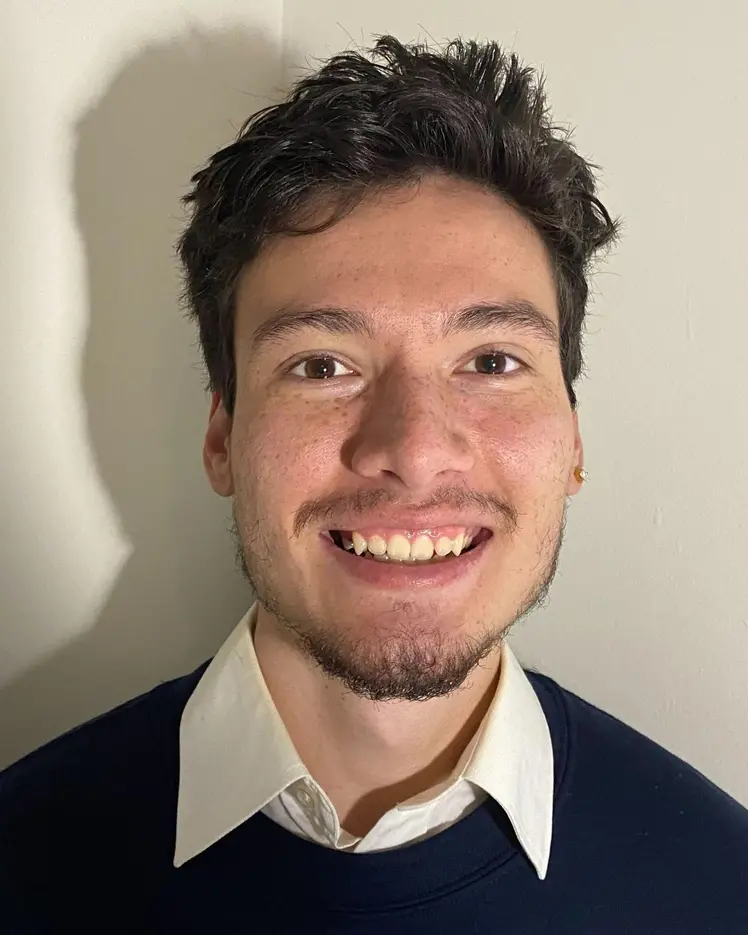
Artur Kuramshin
Master's Research - Université de Montréal
Supervisor
Research Topics
Deep Learning
Robotics
Robustness
Vision and Language


The upcoming meeting, taking place on November 10 at Mila, will explore how we can collectively develop, govern, and deploy high-performing, reliable, and secure agentic systems by connecting academic researchers, industry experts, and practitioners.

Join us on the Venture Scientist Bootcamp, a full time, 4-month incubator at Mila, built specifically for deep tech founders with elite STEM backgrounds. You have until November 21, 2026 to apply!

Mila's annual supervision request process is now open to receive MSc and PhD applications for Fall 2027 admission! Deadline : December 1, 2026.